 ROS Index

|
behaviortree_cpp package from behaviortree_cpp_v3 repobehaviortree_cpp |
ROS Distro
|
Package Summary
| Version | 4.10.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | Behavior Trees Library in C++. Batteries included. |
| Checkout URI | https://github.com/BehaviorTree/BehaviorTree.CPP.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-10-10 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Davide Faconti
Authors
- Davide Faconti


BehaviorTree.CPP 4.9

This C++ 17 library provides a framework to create BehaviorTrees. It was designed to be flexible, easy to use, reactive and fast.
Even if our main use-case is robotics, you can use this library to build AI for games, or to replace Finite State Machines.
There are a few features that make BehaviorTree.CPP unique, when compared to other implementations:
-
It makes asynchronous Actions, i.e. non-blocking, a first-class citizen.
-
You can build reactive behaviors that execute multiple Actions concurrently (orthogonality).
-
Trees are defined using a Domain Specific scripting language (based on XML), and can be loaded at run-time; in other words, even if written in C++, the morphology of the Trees is not hard-coded.
-
You can statically link your custom TreeNodes or convert them into plugins and load them at run-time.
-
It provides a type-safe and flexible mechanism to do Dataflow between Nodes of the Tree.
-
It includes a logging/profiling infrastructure that allows the user to visualize, record, replay, and analyze state transitions.
Documentation
- Tutorials and general documentation: https://www.behaviortree.dev/
- Auto-generated Doxygen: https://behaviortree.github.io/BehaviorTree.CPP/
- Community support and forum: https://github.com/BehaviorTree/BehaviorTree.CPP/discussions
GUI Editor
Editing a BehaviorTree is as simple as editing an XML file in your favorite text editor.
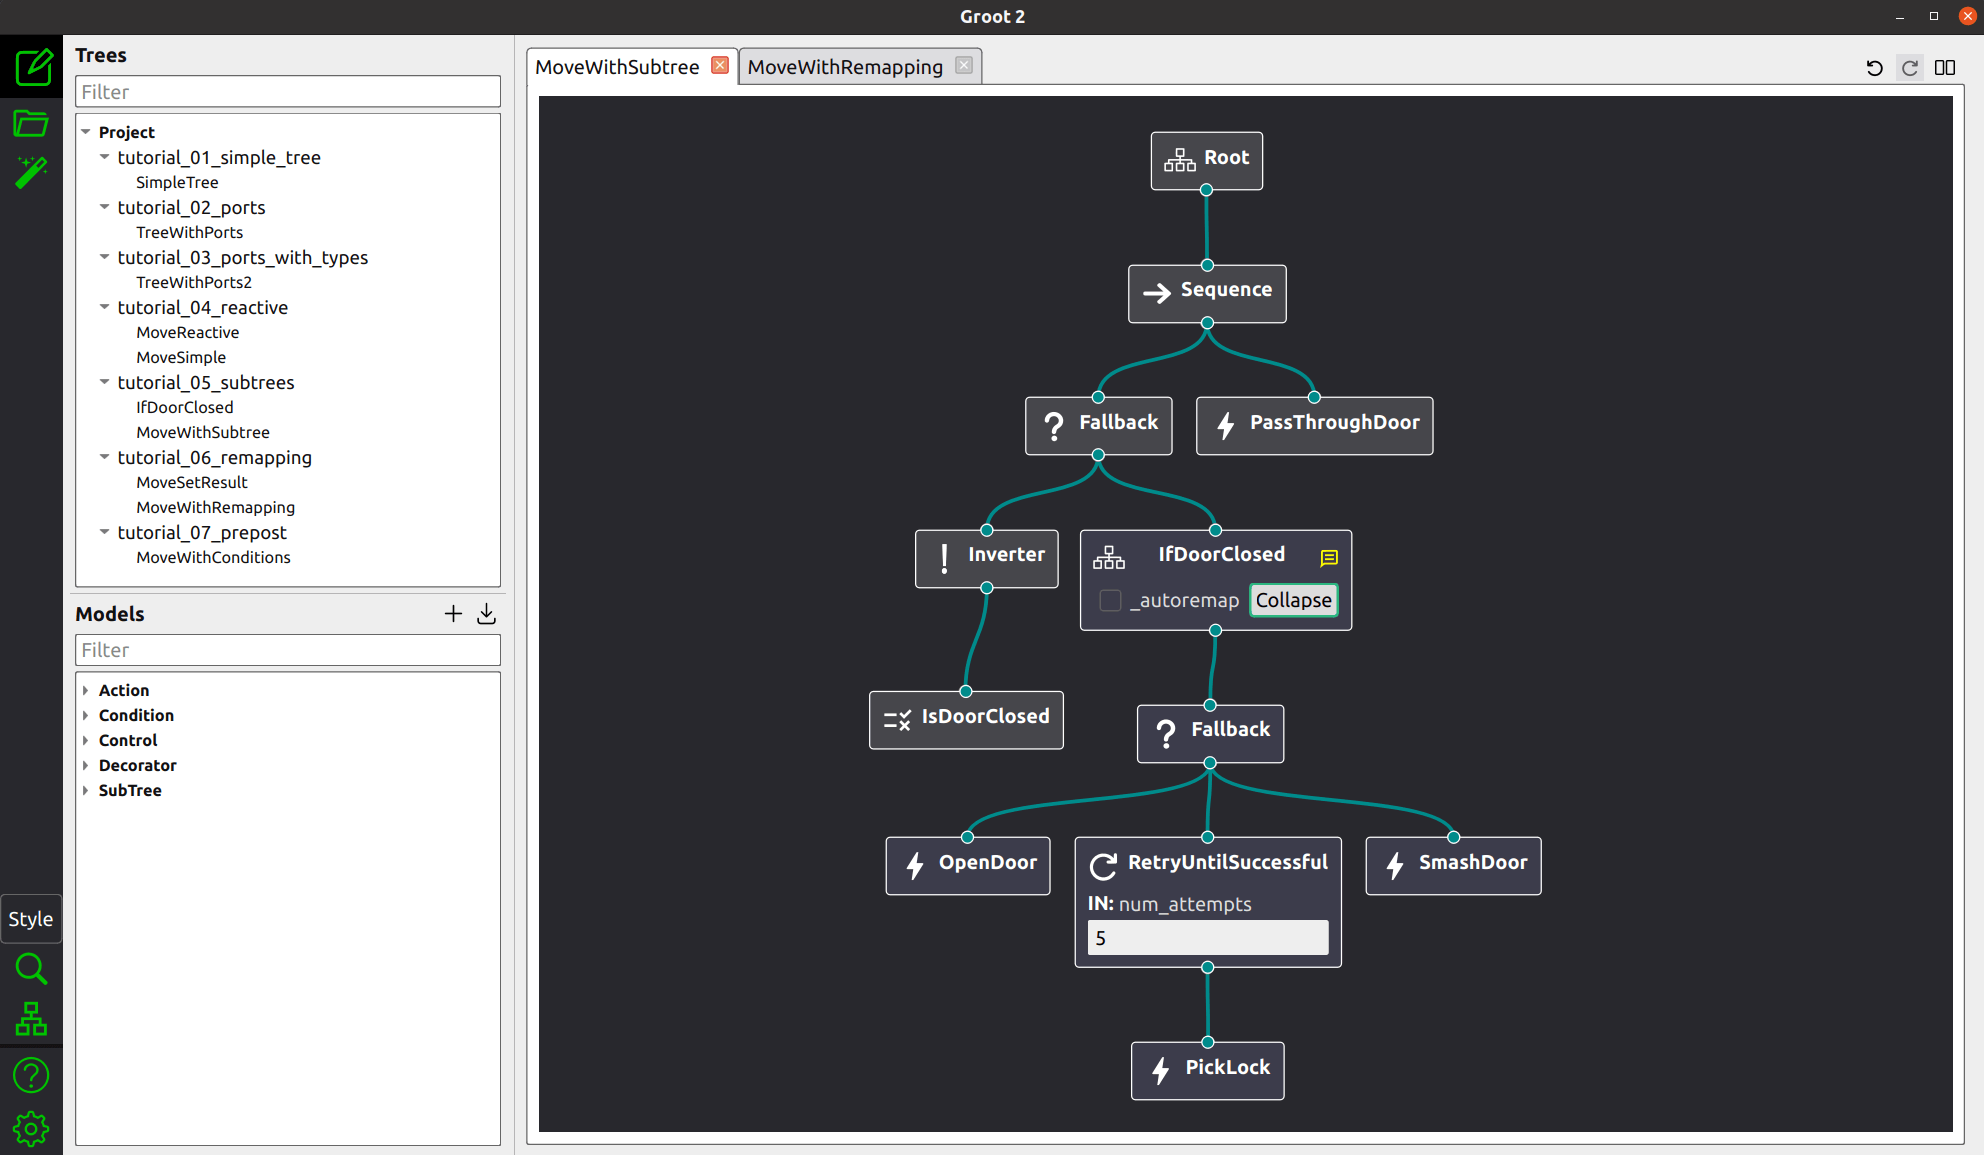
If you are looking for a fancier graphical user interface (and I know you do) check Groot2 out.
How to compile
BT.CPP requires a compiler that supports C++17.
Three build systems are supported:
- colcon (ament), if you use ROS2
- conan otherwise (Linux/Windows).
- straight cmake if you want to be personally responsible for dependencies :)
Compiling with conan:
[!NOTE] Conan builds require CMake 3.23 or newer.
Assuming that you are in the root directory of BehaviorTree.CPP:
conan install . -s build_type=Release --build=missing
cmake --preset conan-release
cmake --build --preset conan-release
If you have dependencies such as ZeroMQ and SQlite already installed and you don’t want to use conan, simply type:
mkdir build_release
cmake -S . -B build_release
cmake --build build_release --parallel
BT.CPP includes its own copy of nlohmann/json.
To use the one installed in your system instead (version 3.10 or newer), add -DUSE_VENDORED_JSON=OFF.
Since nlohmann::json is part of the public API, everything that links BT.CPP must then be
compiled with that same version.
If you want to build in a pixi project (conda virtual environment).
pixi run build
If you want to use BT.CPP in your application, please refer to the example here: https://github.com/BehaviorTree/btcpp_sample .
Installing BehaviorTree.CPP (vcpkg)
Alternatively, you can build and install behaviortree-cpp using vcpkg dependency manager:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
File truncated at 100 lines see the full file
Changelog for package behaviortree_cpp
4.10.0 (2026-07-24)
-
reject trailing characters in SwitchNode numeric comparison (#1178)
-
Pin ament install destinations to lib/include/bin (fixes #1175) (#1176) The ROS build farm (bloom/debhelper) configures with -DCMAKE_INSTALL_LIBDIR=lib/<multiarch-triplet>. Since #1152 made the BTCPP_*_DESTINATION variables honor GNUInstallDirs, farm binaries installed libbehaviortree_cpp.so to /opt/ros/<distro>/lib/x86_64-linux-gnu, which breaks ament_export_libraries lookup in downstream packages and is not on the LD_LIBRARY_PATH set by the ament environment hooks. Shadow the cache variables with plain set() in the ament build path, so ROS builds always install to $prefix/lib regardless of CMAKE_INSTALL_LIBDIR, while standalone builds keep the GNUInstallDirs override behavior introduced for #1120. Also add a ros2-lyrical CI job that emulates the build farm flags and asserts the library lands in $prefix/lib. Co-authored-by: Claude Fable 5 <<noreply@anthropic.com>>
-
fix out-of-bounds read in Groot2 hook insert handler (#1170)
- fix out-of-bounds read in Groot2 hook insert handler
- exclude Parallel.FailingParallel from macOS CI test run
-
Add scripted return status support for TestNode mocks (#1169) Introduce [return_status_script]{.title-ref} on TestNodeConfig, allowing a mock's completion status to be computed at runtime from blackboard state instead of being fixed. When set, it takes precedence over [return_status]{.title-ref}; it may reference the NodeStatus names (SUCCESS/FAILURE/...) and is rejected if it resolves to IDLE. The NodeStatus enum names are injected only into the return_status_script environment. The pre-existing success_script/failure_script/post_script continue to evaluate against the node's own enums, so a blackboard entry named like a status (e.g. "SUCCESS") is not shadowed. To pay the ABI break only once, TestNode's state is moved behind a PImpl, so future changes to it no longer alter the layout consumers link against (mirroring StatusChangeLogger). The new return_status_script field is appended at the end of TestNodeConfig, preserving the byte offsets of the existing fields. Also add JSON validation rejecting a TestNodeConfig with neither a return_status nor a return_status_script, and a tutorial example (t15_nodes_mocking_strict_failure) demonstrating the strict-failure flow. Addresses #995. Co-authored-by: Pepe <<pepe@ross-robotics.co.uk>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Fix ROOT blackboard export in Groot2 publisher (#1132) (#1168) When a subtree's blackboard is backed by a separate root blackboard (e.g. created via [Blackboard::create(external_root)]{.title-ref} to expose [@]{.title-ref} globals), the Groot2 publisher never exported those root entries, so they were invisible in Groot2. Export the root blackboard under the reserved name [ROOT]{.title-ref} whenever a requested subtree resolves to a distinct root blackboard.
- Deduplicate the [ROOT]{.title-ref} payload when several subtrees share the same root blackboard.
- Return the dump as [Expected<>]{.title-ref} and send an error reply for ambiguous requests: a subtree literally named [ROOT]{.title-ref}, or a request spanning multiple distinct root blackboards.
- Add functional coverage to gtest_groot2_publisher_integration.cpp using the shared Groot2Test helpers (makePublisher/Client).
- Enable [/utf-8]{.title-ref} for behaviortree_cpp_test on MSVC so the Unicode name-validation tests build on Windows. Closes #1130 Co-authored-by: magic-alt <<zaqwerss@outlook.com>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Add macOS CI and fix Apple libc++ build (#1167)
* Add macOS build to CI Add a Conan + CMake workflow running on macos-latest (Apple Silicon, AppleClang + libc++). This exercises the Apple standard-library toolchain that other CI jobs (Ubuntu/GCC, Windows/MSVC, conda/Clang) do not, catching Apple-specific breakage such as the missing floating-point std::from_chars. The job mirrors the existing cmake_ubuntu.yml Conan flow (conan install -> cmake --preset conan-release -> ctest), pinning compiler.cppstd=17 as the Windows job does. Co-Authored-By: Claude Opus 4.8 <<noreply@anthropic.com>>
* Fix Apple libc++ build: guard floating-point std::from_chars Apple's libc++ deletes the floating-point std::from_chars overload (and undefines __cpp_lib_to_chars), so the unguarded double parse
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged behaviortree_cpp at Robotics Stack Exchange
|
|
behaviortree_cpp package from behaviortree_cpp_v3 repobehaviortree_cpp |
ROS Distro
|
Package Summary
| Version | 4.10.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | Behavior Trees Library in C++. Batteries included. |
| Checkout URI | https://github.com/BehaviorTree/BehaviorTree.CPP.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-10-10 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Davide Faconti
Authors
- Davide Faconti
BehaviorTree.CPP 4.9
This C++ 17 library provides a framework to create BehaviorTrees. It was designed to be flexible, easy to use, reactive and fast.
Even if our main use-case is robotics, you can use this library to build AI for games, or to replace Finite State Machines.
There are a few features that make BehaviorTree.CPP unique, when compared to other implementations:
-
It makes asynchronous Actions, i.e. non-blocking, a first-class citizen.
-
You can build reactive behaviors that execute multiple Actions concurrently (orthogonality).
-
Trees are defined using a Domain Specific scripting language (based on XML), and can be loaded at run-time; in other words, even if written in C++, the morphology of the Trees is not hard-coded.
-
You can statically link your custom TreeNodes or convert them into plugins and load them at run-time.
-
It provides a type-safe and flexible mechanism to do Dataflow between Nodes of the Tree.
-
It includes a logging/profiling infrastructure that allows the user to visualize, record, replay, and analyze state transitions.
Documentation
- Tutorials and general documentation: https://www.behaviortree.dev/
- Auto-generated Doxygen: https://behaviortree.github.io/BehaviorTree.CPP/
- Community support and forum: https://github.com/BehaviorTree/BehaviorTree.CPP/discussions
GUI Editor
Editing a BehaviorTree is as simple as editing an XML file in your favorite text editor.
If you are looking for a fancier graphical user interface (and I know you do) check Groot2 out.
How to compile
BT.CPP requires a compiler that supports C++17.
Three build systems are supported:
- colcon (ament), if you use ROS2
- conan otherwise (Linux/Windows).
- straight cmake if you want to be personally responsible for dependencies :)
Compiling with conan:
[!NOTE] Conan builds require CMake 3.23 or newer.
Assuming that you are in the root directory of BehaviorTree.CPP:
conan install . -s build_type=Release --build=missing
cmake --preset conan-release
cmake --build --preset conan-release
If you have dependencies such as ZeroMQ and SQlite already installed and you don’t want to use conan, simply type:
mkdir build_release
cmake -S . -B build_release
cmake --build build_release --parallel
BT.CPP includes its own copy of nlohmann/json.
To use the one installed in your system instead (version 3.10 or newer), add -DUSE_VENDORED_JSON=OFF.
Since nlohmann::json is part of the public API, everything that links BT.CPP must then be
compiled with that same version.
If you want to build in a pixi project (conda virtual environment).
pixi run build
If you want to use BT.CPP in your application, please refer to the example here: https://github.com/BehaviorTree/btcpp_sample .
Installing BehaviorTree.CPP (vcpkg)
Alternatively, you can build and install behaviortree-cpp using vcpkg dependency manager:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
File truncated at 100 lines see the full file
Changelog for package behaviortree_cpp
4.10.0 (2026-07-24)
-
reject trailing characters in SwitchNode numeric comparison (#1178)
-
Pin ament install destinations to lib/include/bin (fixes #1175) (#1176) The ROS build farm (bloom/debhelper) configures with -DCMAKE_INSTALL_LIBDIR=lib/<multiarch-triplet>. Since #1152 made the BTCPP_*_DESTINATION variables honor GNUInstallDirs, farm binaries installed libbehaviortree_cpp.so to /opt/ros/<distro>/lib/x86_64-linux-gnu, which breaks ament_export_libraries lookup in downstream packages and is not on the LD_LIBRARY_PATH set by the ament environment hooks. Shadow the cache variables with plain set() in the ament build path, so ROS builds always install to $prefix/lib regardless of CMAKE_INSTALL_LIBDIR, while standalone builds keep the GNUInstallDirs override behavior introduced for #1120. Also add a ros2-lyrical CI job that emulates the build farm flags and asserts the library lands in $prefix/lib. Co-authored-by: Claude Fable 5 <<noreply@anthropic.com>>
-
fix out-of-bounds read in Groot2 hook insert handler (#1170)
- fix out-of-bounds read in Groot2 hook insert handler
- exclude Parallel.FailingParallel from macOS CI test run
-
Add scripted return status support for TestNode mocks (#1169) Introduce [return_status_script]{.title-ref} on TestNodeConfig, allowing a mock's completion status to be computed at runtime from blackboard state instead of being fixed. When set, it takes precedence over [return_status]{.title-ref}; it may reference the NodeStatus names (SUCCESS/FAILURE/...) and is rejected if it resolves to IDLE. The NodeStatus enum names are injected only into the return_status_script environment. The pre-existing success_script/failure_script/post_script continue to evaluate against the node's own enums, so a blackboard entry named like a status (e.g. "SUCCESS") is not shadowed. To pay the ABI break only once, TestNode's state is moved behind a PImpl, so future changes to it no longer alter the layout consumers link against (mirroring StatusChangeLogger). The new return_status_script field is appended at the end of TestNodeConfig, preserving the byte offsets of the existing fields. Also add JSON validation rejecting a TestNodeConfig with neither a return_status nor a return_status_script, and a tutorial example (t15_nodes_mocking_strict_failure) demonstrating the strict-failure flow. Addresses #995. Co-authored-by: Pepe <<pepe@ross-robotics.co.uk>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Fix ROOT blackboard export in Groot2 publisher (#1132) (#1168) When a subtree's blackboard is backed by a separate root blackboard (e.g. created via [Blackboard::create(external_root)]{.title-ref} to expose [@]{.title-ref} globals), the Groot2 publisher never exported those root entries, so they were invisible in Groot2. Export the root blackboard under the reserved name [ROOT]{.title-ref} whenever a requested subtree resolves to a distinct root blackboard.
- Deduplicate the [ROOT]{.title-ref} payload when several subtrees share the same root blackboard.
- Return the dump as [Expected<>]{.title-ref} and send an error reply for ambiguous requests: a subtree literally named [ROOT]{.title-ref}, or a request spanning multiple distinct root blackboards.
- Add functional coverage to gtest_groot2_publisher_integration.cpp using the shared Groot2Test helpers (makePublisher/Client).
- Enable [/utf-8]{.title-ref} for behaviortree_cpp_test on MSVC so the Unicode name-validation tests build on Windows. Closes #1130 Co-authored-by: magic-alt <<zaqwerss@outlook.com>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Add macOS CI and fix Apple libc++ build (#1167)
* Add macOS build to CI Add a Conan + CMake workflow running on macos-latest (Apple Silicon, AppleClang + libc++). This exercises the Apple standard-library toolchain that other CI jobs (Ubuntu/GCC, Windows/MSVC, conda/Clang) do not, catching Apple-specific breakage such as the missing floating-point std::from_chars. The job mirrors the existing cmake_ubuntu.yml Conan flow (conan install -> cmake --preset conan-release -> ctest), pinning compiler.cppstd=17 as the Windows job does. Co-Authored-By: Claude Opus 4.8 <<noreply@anthropic.com>>
* Fix Apple libc++ build: guard floating-point std::from_chars Apple's libc++ deletes the floating-point std::from_chars overload (and undefines __cpp_lib_to_chars), so the unguarded double parse
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged behaviortree_cpp at Robotics Stack Exchange
|
|
behaviortree_cpp package from behaviortree_cpp_v3 repobehaviortree_cpp |
ROS Distro
|
Package Summary
| Version | 4.10.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | Behavior Trees Library in C++. Batteries included. |
| Checkout URI | https://github.com/BehaviorTree/BehaviorTree.CPP.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-10-10 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Davide Faconti
Authors
- Davide Faconti
BehaviorTree.CPP 4.9
This C++ 17 library provides a framework to create BehaviorTrees. It was designed to be flexible, easy to use, reactive and fast.
Even if our main use-case is robotics, you can use this library to build AI for games, or to replace Finite State Machines.
There are a few features that make BehaviorTree.CPP unique, when compared to other implementations:
-
It makes asynchronous Actions, i.e. non-blocking, a first-class citizen.
-
You can build reactive behaviors that execute multiple Actions concurrently (orthogonality).
-
Trees are defined using a Domain Specific scripting language (based on XML), and can be loaded at run-time; in other words, even if written in C++, the morphology of the Trees is not hard-coded.
-
You can statically link your custom TreeNodes or convert them into plugins and load them at run-time.
-
It provides a type-safe and flexible mechanism to do Dataflow between Nodes of the Tree.
-
It includes a logging/profiling infrastructure that allows the user to visualize, record, replay, and analyze state transitions.
Documentation
- Tutorials and general documentation: https://www.behaviortree.dev/
- Auto-generated Doxygen: https://behaviortree.github.io/BehaviorTree.CPP/
- Community support and forum: https://github.com/BehaviorTree/BehaviorTree.CPP/discussions
GUI Editor
Editing a BehaviorTree is as simple as editing an XML file in your favorite text editor.
If you are looking for a fancier graphical user interface (and I know you do) check Groot2 out.
How to compile
BT.CPP requires a compiler that supports C++17.
Three build systems are supported:
- colcon (ament), if you use ROS2
- conan otherwise (Linux/Windows).
- straight cmake if you want to be personally responsible for dependencies :)
Compiling with conan:
[!NOTE] Conan builds require CMake 3.23 or newer.
Assuming that you are in the root directory of BehaviorTree.CPP:
conan install . -s build_type=Release --build=missing
cmake --preset conan-release
cmake --build --preset conan-release
If you have dependencies such as ZeroMQ and SQlite already installed and you don’t want to use conan, simply type:
mkdir build_release
cmake -S . -B build_release
cmake --build build_release --parallel
BT.CPP includes its own copy of nlohmann/json.
To use the one installed in your system instead (version 3.10 or newer), add -DUSE_VENDORED_JSON=OFF.
Since nlohmann::json is part of the public API, everything that links BT.CPP must then be
compiled with that same version.
If you want to build in a pixi project (conda virtual environment).
pixi run build
If you want to use BT.CPP in your application, please refer to the example here: https://github.com/BehaviorTree/btcpp_sample .
Installing BehaviorTree.CPP (vcpkg)
Alternatively, you can build and install behaviortree-cpp using vcpkg dependency manager:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
File truncated at 100 lines see the full file
Changelog for package behaviortree_cpp
4.10.0 (2026-07-24)
-
reject trailing characters in SwitchNode numeric comparison (#1178)
-
Pin ament install destinations to lib/include/bin (fixes #1175) (#1176) The ROS build farm (bloom/debhelper) configures with -DCMAKE_INSTALL_LIBDIR=lib/<multiarch-triplet>. Since #1152 made the BTCPP_*_DESTINATION variables honor GNUInstallDirs, farm binaries installed libbehaviortree_cpp.so to /opt/ros/<distro>/lib/x86_64-linux-gnu, which breaks ament_export_libraries lookup in downstream packages and is not on the LD_LIBRARY_PATH set by the ament environment hooks. Shadow the cache variables with plain set() in the ament build path, so ROS builds always install to $prefix/lib regardless of CMAKE_INSTALL_LIBDIR, while standalone builds keep the GNUInstallDirs override behavior introduced for #1120. Also add a ros2-lyrical CI job that emulates the build farm flags and asserts the library lands in $prefix/lib. Co-authored-by: Claude Fable 5 <<noreply@anthropic.com>>
-
fix out-of-bounds read in Groot2 hook insert handler (#1170)
- fix out-of-bounds read in Groot2 hook insert handler
- exclude Parallel.FailingParallel from macOS CI test run
-
Add scripted return status support for TestNode mocks (#1169) Introduce [return_status_script]{.title-ref} on TestNodeConfig, allowing a mock's completion status to be computed at runtime from blackboard state instead of being fixed. When set, it takes precedence over [return_status]{.title-ref}; it may reference the NodeStatus names (SUCCESS/FAILURE/...) and is rejected if it resolves to IDLE. The NodeStatus enum names are injected only into the return_status_script environment. The pre-existing success_script/failure_script/post_script continue to evaluate against the node's own enums, so a blackboard entry named like a status (e.g. "SUCCESS") is not shadowed. To pay the ABI break only once, TestNode's state is moved behind a PImpl, so future changes to it no longer alter the layout consumers link against (mirroring StatusChangeLogger). The new return_status_script field is appended at the end of TestNodeConfig, preserving the byte offsets of the existing fields. Also add JSON validation rejecting a TestNodeConfig with neither a return_status nor a return_status_script, and a tutorial example (t15_nodes_mocking_strict_failure) demonstrating the strict-failure flow. Addresses #995. Co-authored-by: Pepe <<pepe@ross-robotics.co.uk>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Fix ROOT blackboard export in Groot2 publisher (#1132) (#1168) When a subtree's blackboard is backed by a separate root blackboard (e.g. created via [Blackboard::create(external_root)]{.title-ref} to expose [@]{.title-ref} globals), the Groot2 publisher never exported those root entries, so they were invisible in Groot2. Export the root blackboard under the reserved name [ROOT]{.title-ref} whenever a requested subtree resolves to a distinct root blackboard.
- Deduplicate the [ROOT]{.title-ref} payload when several subtrees share the same root blackboard.
- Return the dump as [Expected<>]{.title-ref} and send an error reply for ambiguous requests: a subtree literally named [ROOT]{.title-ref}, or a request spanning multiple distinct root blackboards.
- Add functional coverage to gtest_groot2_publisher_integration.cpp using the shared Groot2Test helpers (makePublisher/Client).
- Enable [/utf-8]{.title-ref} for behaviortree_cpp_test on MSVC so the Unicode name-validation tests build on Windows. Closes #1130 Co-authored-by: magic-alt <<zaqwerss@outlook.com>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Add macOS CI and fix Apple libc++ build (#1167)
* Add macOS build to CI Add a Conan + CMake workflow running on macos-latest (Apple Silicon, AppleClang + libc++). This exercises the Apple standard-library toolchain that other CI jobs (Ubuntu/GCC, Windows/MSVC, conda/Clang) do not, catching Apple-specific breakage such as the missing floating-point std::from_chars. The job mirrors the existing cmake_ubuntu.yml Conan flow (conan install -> cmake --preset conan-release -> ctest), pinning compiler.cppstd=17 as the Windows job does. Co-Authored-By: Claude Opus 4.8 <<noreply@anthropic.com>>
* Fix Apple libc++ build: guard floating-point std::from_chars Apple's libc++ deletes the floating-point std::from_chars overload (and undefines __cpp_lib_to_chars), so the unguarded double parse
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
| Name | Deps |
|---|---|
| nav2_bt_navigator | |
| nav2_mission_executor | |
| nav2_tasks |
Launch files
Messages
Services
Plugins
Recent questions tagged behaviortree_cpp at Robotics Stack Exchange
|
|
behaviortree_cpp package from behaviortree_cpp_v3 repobehaviortree_cpp |
ROS Distro
|
Package Summary
| Version | 4.10.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | Behavior Trees Library in C++. Batteries included. |
| Checkout URI | https://github.com/BehaviorTree/BehaviorTree.CPP.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-10-10 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Davide Faconti
Authors
- Davide Faconti
BehaviorTree.CPP 4.9
This C++ 17 library provides a framework to create BehaviorTrees. It was designed to be flexible, easy to use, reactive and fast.
Even if our main use-case is robotics, you can use this library to build AI for games, or to replace Finite State Machines.
There are a few features that make BehaviorTree.CPP unique, when compared to other implementations:
-
It makes asynchronous Actions, i.e. non-blocking, a first-class citizen.
-
You can build reactive behaviors that execute multiple Actions concurrently (orthogonality).
-
Trees are defined using a Domain Specific scripting language (based on XML), and can be loaded at run-time; in other words, even if written in C++, the morphology of the Trees is not hard-coded.
-
You can statically link your custom TreeNodes or convert them into plugins and load them at run-time.
-
It provides a type-safe and flexible mechanism to do Dataflow between Nodes of the Tree.
-
It includes a logging/profiling infrastructure that allows the user to visualize, record, replay, and analyze state transitions.
Documentation
- Tutorials and general documentation: https://www.behaviortree.dev/
- Auto-generated Doxygen: https://behaviortree.github.io/BehaviorTree.CPP/
- Community support and forum: https://github.com/BehaviorTree/BehaviorTree.CPP/discussions
GUI Editor
Editing a BehaviorTree is as simple as editing an XML file in your favorite text editor.
If you are looking for a fancier graphical user interface (and I know you do) check Groot2 out.
How to compile
BT.CPP requires a compiler that supports C++17.
Three build systems are supported:
- colcon (ament), if you use ROS2
- conan otherwise (Linux/Windows).
- straight cmake if you want to be personally responsible for dependencies :)
Compiling with conan:
[!NOTE] Conan builds require CMake 3.23 or newer.
Assuming that you are in the root directory of BehaviorTree.CPP:
conan install . -s build_type=Release --build=missing
cmake --preset conan-release
cmake --build --preset conan-release
If you have dependencies such as ZeroMQ and SQlite already installed and you don’t want to use conan, simply type:
mkdir build_release
cmake -S . -B build_release
cmake --build build_release --parallel
BT.CPP includes its own copy of nlohmann/json.
To use the one installed in your system instead (version 3.10 or newer), add -DUSE_VENDORED_JSON=OFF.
Since nlohmann::json is part of the public API, everything that links BT.CPP must then be
compiled with that same version.
If you want to build in a pixi project (conda virtual environment).
pixi run build
If you want to use BT.CPP in your application, please refer to the example here: https://github.com/BehaviorTree/btcpp_sample .
Installing BehaviorTree.CPP (vcpkg)
Alternatively, you can build and install behaviortree-cpp using vcpkg dependency manager:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
File truncated at 100 lines see the full file
Changelog for package behaviortree_cpp
4.10.0 (2026-07-24)
-
reject trailing characters in SwitchNode numeric comparison (#1178)
-
Pin ament install destinations to lib/include/bin (fixes #1175) (#1176) The ROS build farm (bloom/debhelper) configures with -DCMAKE_INSTALL_LIBDIR=lib/<multiarch-triplet>. Since #1152 made the BTCPP_*_DESTINATION variables honor GNUInstallDirs, farm binaries installed libbehaviortree_cpp.so to /opt/ros/<distro>/lib/x86_64-linux-gnu, which breaks ament_export_libraries lookup in downstream packages and is not on the LD_LIBRARY_PATH set by the ament environment hooks. Shadow the cache variables with plain set() in the ament build path, so ROS builds always install to $prefix/lib regardless of CMAKE_INSTALL_LIBDIR, while standalone builds keep the GNUInstallDirs override behavior introduced for #1120. Also add a ros2-lyrical CI job that emulates the build farm flags and asserts the library lands in $prefix/lib. Co-authored-by: Claude Fable 5 <<noreply@anthropic.com>>
-
fix out-of-bounds read in Groot2 hook insert handler (#1170)
- fix out-of-bounds read in Groot2 hook insert handler
- exclude Parallel.FailingParallel from macOS CI test run
-
Add scripted return status support for TestNode mocks (#1169) Introduce [return_status_script]{.title-ref} on TestNodeConfig, allowing a mock's completion status to be computed at runtime from blackboard state instead of being fixed. When set, it takes precedence over [return_status]{.title-ref}; it may reference the NodeStatus names (SUCCESS/FAILURE/...) and is rejected if it resolves to IDLE. The NodeStatus enum names are injected only into the return_status_script environment. The pre-existing success_script/failure_script/post_script continue to evaluate against the node's own enums, so a blackboard entry named like a status (e.g. "SUCCESS") is not shadowed. To pay the ABI break only once, TestNode's state is moved behind a PImpl, so future changes to it no longer alter the layout consumers link against (mirroring StatusChangeLogger). The new return_status_script field is appended at the end of TestNodeConfig, preserving the byte offsets of the existing fields. Also add JSON validation rejecting a TestNodeConfig with neither a return_status nor a return_status_script, and a tutorial example (t15_nodes_mocking_strict_failure) demonstrating the strict-failure flow. Addresses #995. Co-authored-by: Pepe <<pepe@ross-robotics.co.uk>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Fix ROOT blackboard export in Groot2 publisher (#1132) (#1168) When a subtree's blackboard is backed by a separate root blackboard (e.g. created via [Blackboard::create(external_root)]{.title-ref} to expose [@]{.title-ref} globals), the Groot2 publisher never exported those root entries, so they were invisible in Groot2. Export the root blackboard under the reserved name [ROOT]{.title-ref} whenever a requested subtree resolves to a distinct root blackboard.
- Deduplicate the [ROOT]{.title-ref} payload when several subtrees share the same root blackboard.
- Return the dump as [Expected<>]{.title-ref} and send an error reply for ambiguous requests: a subtree literally named [ROOT]{.title-ref}, or a request spanning multiple distinct root blackboards.
- Add functional coverage to gtest_groot2_publisher_integration.cpp using the shared Groot2Test helpers (makePublisher/Client).
- Enable [/utf-8]{.title-ref} for behaviortree_cpp_test on MSVC so the Unicode name-validation tests build on Windows. Closes #1130 Co-authored-by: magic-alt <<zaqwerss@outlook.com>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Add macOS CI and fix Apple libc++ build (#1167)
* Add macOS build to CI Add a Conan + CMake workflow running on macos-latest (Apple Silicon, AppleClang + libc++). This exercises the Apple standard-library toolchain that other CI jobs (Ubuntu/GCC, Windows/MSVC, conda/Clang) do not, catching Apple-specific breakage such as the missing floating-point std::from_chars. The job mirrors the existing cmake_ubuntu.yml Conan flow (conan install -> cmake --preset conan-release -> ctest), pinning compiler.cppstd=17 as the Windows job does. Co-Authored-By: Claude Opus 4.8 <<noreply@anthropic.com>>
* Fix Apple libc++ build: guard floating-point std::from_chars Apple's libc++ deletes the floating-point std::from_chars overload (and undefines __cpp_lib_to_chars), so the unguarded double parse
File truncated at 100 lines see the full file
Package Dependencies
System Dependencies
Dependant Packages
Launch files
Messages
Services
Plugins
Recent questions tagged behaviortree_cpp at Robotics Stack Exchange
|
|
behaviortree_cpp package from behaviortree_cpp_v3 repobehaviortree_cpp |
ROS Distro
|
Package Summary
| Version | 4.10.0 |
| License | MIT |
| Build type | AMENT_CMAKE |
| Use | RECOMMENDED |
Repository Summary
| Description | Behavior Trees Library in C++. Batteries included. |
| Checkout URI | https://github.com/BehaviorTree/BehaviorTree.CPP.git |
| VCS Type | git |
| VCS Version | master |
| Last Updated | 2026-10-10 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Package Description
Maintainers
- Davide Faconti
Authors
- Davide Faconti
BehaviorTree.CPP 4.9
This C++ 17 library provides a framework to create BehaviorTrees. It was designed to be flexible, easy to use, reactive and fast.
Even if our main use-case is robotics, you can use this library to build AI for games, or to replace Finite State Machines.
There are a few features that make BehaviorTree.CPP unique, when compared to other implementations:
-
It makes asynchronous Actions, i.e. non-blocking, a first-class citizen.
-
You can build reactive behaviors that execute multiple Actions concurrently (orthogonality).
-
Trees are defined using a Domain Specific scripting language (based on XML), and can be loaded at run-time; in other words, even if written in C++, the morphology of the Trees is not hard-coded.
-
You can statically link your custom TreeNodes or convert them into plugins and load them at run-time.
-
It provides a type-safe and flexible mechanism to do Dataflow between Nodes of the Tree.
-
It includes a logging/profiling infrastructure that allows the user to visualize, record, replay, and analyze state transitions.
Documentation
- Tutorials and general documentation: https://www.behaviortree.dev/
- Auto-generated Doxygen: https://behaviortree.github.io/BehaviorTree.CPP/
- Community support and forum: https://github.com/BehaviorTree/BehaviorTree.CPP/discussions
GUI Editor
Editing a BehaviorTree is as simple as editing an XML file in your favorite text editor.
If you are looking for a fancier graphical user interface (and I know you do) check Groot2 out.
How to compile
BT.CPP requires a compiler that supports C++17.
Three build systems are supported:
- colcon (ament), if you use ROS2
- conan otherwise (Linux/Windows).
- straight cmake if you want to be personally responsible for dependencies :)
Compiling with conan:
[!NOTE] Conan builds require CMake 3.23 or newer.
Assuming that you are in the root directory of BehaviorTree.CPP:
conan install . -s build_type=Release --build=missing
cmake --preset conan-release
cmake --build --preset conan-release
If you have dependencies such as ZeroMQ and SQlite already installed and you don’t want to use conan, simply type:
mkdir build_release
cmake -S . -B build_release
cmake --build build_release --parallel
BT.CPP includes its own copy of nlohmann/json.
To use the one installed in your system instead (version 3.10 or newer), add -DUSE_VENDORED_JSON=OFF.
Since nlohmann::json is part of the public API, everything that links BT.CPP must then be
compiled with that same version.
If you want to build in a pixi project (conda virtual environment).
pixi run build
If you want to use BT.CPP in your application, please refer to the example here: https://github.com/BehaviorTree/btcpp_sample .
Installing BehaviorTree.CPP (vcpkg)
Alternatively, you can build and install behaviortree-cpp using vcpkg dependency manager:
git clone https://github.com/Microsoft/vcpkg.git
cd vcpkg
File truncated at 100 lines see the full file
Changelog for package behaviortree_cpp
4.10.0 (2026-07-24)
-
reject trailing characters in SwitchNode numeric comparison (#1178)
-
Pin ament install destinations to lib/include/bin (fixes #1175) (#1176) The ROS build farm (bloom/debhelper) configures with -DCMAKE_INSTALL_LIBDIR=lib/<multiarch-triplet>. Since #1152 made the BTCPP_*_DESTINATION variables honor GNUInstallDirs, farm binaries installed libbehaviortree_cpp.so to /opt/ros/<distro>/lib/x86_64-linux-gnu, which breaks ament_export_libraries lookup in downstream packages and is not on the LD_LIBRARY_PATH set by the ament environment hooks. Shadow the cache variables with plain set() in the ament build path, so ROS builds always install to $prefix/lib regardless of CMAKE_INSTALL_LIBDIR, while standalone builds keep the GNUInstallDirs override behavior introduced for #1120. Also add a ros2-lyrical CI job that emulates the build farm flags and asserts the library lands in $prefix/lib. Co-authored-by: Claude Fable 5 <<noreply@anthropic.com>>
-
fix out-of-bounds read in Groot2 hook insert handler (#1170)
- fix out-of-bounds read in Groot2 hook insert handler
- exclude Parallel.FailingParallel from macOS CI test run
-
Add scripted return status support for TestNode mocks (#1169) Introduce [return_status_script]{.title-ref} on TestNodeConfig, allowing a mock's completion status to be computed at runtime from blackboard state instead of being fixed. When set, it takes precedence over [return_status]{.title-ref}; it may reference the NodeStatus names (SUCCESS/FAILURE/...) and is rejected if it resolves to IDLE. The NodeStatus enum names are injected only into the return_status_script environment. The pre-existing success_script/failure_script/post_script continue to evaluate against the node's own enums, so a blackboard entry named like a status (e.g. "SUCCESS") is not shadowed. To pay the ABI break only once, TestNode's state is moved behind a PImpl, so future changes to it no longer alter the layout consumers link against (mirroring StatusChangeLogger). The new return_status_script field is appended at the end of TestNodeConfig, preserving the byte offsets of the existing fields. Also add JSON validation rejecting a TestNodeConfig with neither a return_status nor a return_status_script, and a tutorial example (t15_nodes_mocking_strict_failure) demonstrating the strict-failure flow. Addresses #995. Co-authored-by: Pepe <<pepe@ross-robotics.co.uk>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Fix ROOT blackboard export in Groot2 publisher (#1132) (#1168) When a subtree's blackboard is backed by a separate root blackboard (e.g. created via [Blackboard::create(external_root)]{.title-ref} to expose [@]{.title-ref} globals), the Groot2 publisher never exported those root entries, so they were invisible in Groot2. Export the root blackboard under the reserved name [ROOT]{.title-ref} whenever a requested subtree resolves to a distinct root blackboard.
- Deduplicate the [ROOT]{.title-ref} payload when several subtrees share the same root blackboard.
- Return the dump as [Expected<>]{.title-ref} and send an error reply for ambiguous requests: a subtree literally named [ROOT]{.title-ref}, or a request spanning multiple distinct root blackboards.
- Add functional coverage to gtest_groot2_publisher_integration.cpp using the shared Groot2Test helpers (makePublisher/Client).
- Enable [/utf-8]{.title-ref} for behaviortree_cpp_test on MSVC so the Unicode name-validation tests build on Windows. Closes #1130 Co-authored-by: magic-alt <<zaqwerss@outlook.com>> Co-authored-by: Claude Opus 4.8 <<noreply@anthropic.com>>
-
Add macOS CI and fix Apple libc++ build (#1167)
* Add macOS build to CI Add a Conan + CMake workflow running on macos-latest (Apple Silicon, AppleClang + libc++). This exercises the Apple standard-library toolchain that other CI jobs (Ubuntu/GCC, Windows/MSVC, conda/Clang) do not, catching Apple-specific breakage such as the missing floating-point std::from_chars. The job mirrors the existing cmake_ubuntu.yml Conan flow (conan install -> cmake --preset conan-release -> ctest), pinning compiler.cppstd=17 as the Windows job does. Co-Authored-By: Claude Opus 4.8 <<noreply@anthropic.com>>
* Fix Apple libc++ build: guard floating-point std::from_chars Apple's libc++ deletes the floating-point std::from_chars overload (and undefines __cpp_lib_to_chars), so the unguarded double parse
File truncated at 100 lines see the full file