 ROS Index

|
NavMap repositorynavmap_core navmap_examples navmap_ros navmap_ros_interfaces navmap_rviz_plugin navmap_tools |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/NavMap.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| navmap_core | 0.6.0 |
| navmap_examples | 0.6.0 |
| navmap_ros | 0.6.0 |
| navmap_ros_interfaces | 0.6.0 |
| navmap_rviz_plugin | 0.6.0 |
| navmap_tools | 0.6.0 |
README
NavMap


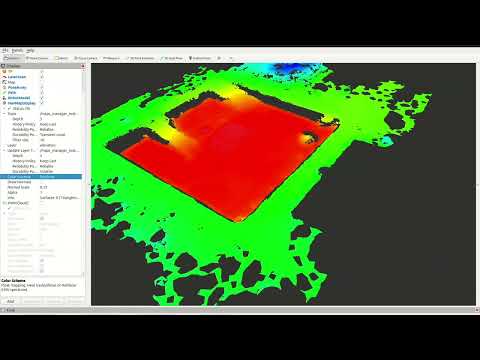
NavMap is an open-source C++ and ROS 2 library for representing navigable surfaces for mobile robot navigation and localization. Unlike classic grid-based maps, NavMap stores the environment as triangular meshes (NavCels), enabling efficient queries and multi-surface environments (e.g., multi-floor buildings).
Funded by the European Union through the Horizon Europe programme under Grant Agreement No. 101070254 (CoreSense), and by MICIU/AEI/10.13039/501100011033 and ERDF/EU under grants PERMAP PID2024-161761OB-C21 and PLANNAV PID2024-161761OB-C22 (AURORAS).
✨ Features
- Triangular cell mesh representation with adjacency relations.
- Dynamic runtime layers: per-cell or per-vertex attributes (occupancy, elevation, cost, traversability, etc.).
- Locate API: find the NavCel under/around a 3D position using BVH acceleration and raycasting.
- Raytracing: Möller–Trumbore intersection with a simple BVH for efficiency.
- Multi-surface support: naturally supports multiple disconnected surfaces (e.g., separate floors).
📂 Repository structure
This repository is organized into several ROS 2 packages:
-
navmap_core/
Core C++ library implementing NavMap. Minimal dependencies (Eigen3). -
navmap_ros/
ROS 2 conversions and message definitions:-
navmap::NavMap↔navmap_ros_interfaces::msg::NavMap -
nav_msgs::msg::OccupancyGrid↔navmap::NavMap
-
-
navmap_rviz_plugin/
RViz2 plugin for visualization of NavMap messages:- Displays surfaces and layers.
- Optional per-cell normal rendering.
- Layer-based coloring.
-
navmap_tools/
Tools and utilities for building and testing NavMaps (mesh import/export, conversions, etc.) -
navmap_examples/
Practical examples demonstrating the usage of NavMap, both core C++ API and ROS 2 integrations.
⚙️ Build instructions
NavMap can be built as a standalone C++ library or within a ROS 2 workspace.
ROS 2 colcon build
# Clone into your ROS 2 workspace
cd ~/ros2_ws/src
git clone https://github.com/<your-org>/NavMap.git

# Build
cd ~/ros2_ws
colcon build --packages-up-to navmap_core navmap_ros navmap_rviz_plugin navmap_tools navmap_examples

# Source workspace
source install/setup.bash
Dependencies
- C++23 compiler
- Eigen3
- ROS 2 (tested with Humble, Iron, Jazzy)
- RViz2 (for the visualization plugin)
- PCL (for mesh construction utilities)
🚀 Usage (C++ API)
This section shows small, self-contained snippets that demonstrate how to create a NavMap, add geometry, attach layers, query values, and locate the triangle (NavCel) corresponding to a 3D position.
Note: After modifying geometry (vertices, triangles, or surfaces), always call
rebuild_geometry_accels()before performing queries such aslocate_navcel()orraycast().
1. Create a minimal NavMap (single square floor with two triangles)
```cpp
File truncated at 100 lines see the full file
CONTRIBUTING
|
|
NavMap repositorynavmap_core navmap_examples navmap_ros navmap_ros_interfaces navmap_rviz_plugin navmap_tools |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/NavMap.git |
| VCS Type | git |
| VCS Version | jazzy |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| navmap_core | 0.6.0 |
| navmap_examples | 0.6.0 |
| navmap_ros | 0.6.0 |
| navmap_ros_interfaces | 0.6.0 |
| navmap_rviz_plugin | 0.6.0 |
| navmap_tools | 0.6.0 |
README
NavMap
NavMap is an open-source C++ and ROS 2 library for representing navigable surfaces for mobile robot navigation and localization. Unlike classic grid-based maps, NavMap stores the environment as triangular meshes (NavCels), enabling efficient queries and multi-surface environments (e.g., multi-floor buildings).
Funded by the European Union through the Horizon Europe programme under Grant Agreement No. 101070254 (CoreSense), and by MICIU/AEI/10.13039/501100011033 and ERDF/EU under grants PERMAP PID2024-161761OB-C21 and PLANNAV PID2024-161761OB-C22 (AURORAS).
✨ Features
- Triangular cell mesh representation with adjacency relations.
- Dynamic runtime layers: per-cell or per-vertex attributes (occupancy, elevation, cost, traversability, etc.).
- Locate API: find the NavCel under/around a 3D position using BVH acceleration and raycasting.
- Raytracing: Möller–Trumbore intersection with a simple BVH for efficiency.
- Multi-surface support: naturally supports multiple disconnected surfaces (e.g., separate floors).
📂 Repository structure
This repository is organized into several ROS 2 packages:
-
navmap_core/
Core C++ library implementing NavMap. Minimal dependencies (Eigen3). -
navmap_ros/
ROS 2 conversions and message definitions:-
navmap::NavMap↔navmap_ros_interfaces::msg::NavMap -
nav_msgs::msg::OccupancyGrid↔navmap::NavMap
-
-
navmap_rviz_plugin/
RViz2 plugin for visualization of NavMap messages:- Displays surfaces and layers.
- Optional per-cell normal rendering.
- Layer-based coloring.
-
navmap_tools/
Tools and utilities for building and testing NavMaps (mesh import/export, conversions, etc.) -
navmap_examples/
Practical examples demonstrating the usage of NavMap, both core C++ API and ROS 2 integrations.
⚙️ Build instructions
NavMap can be built as a standalone C++ library or within a ROS 2 workspace.
ROS 2 colcon build
# Clone into your ROS 2 workspace
cd ~/ros2_ws/src
git clone https://github.com/<your-org>/NavMap.git

# Build
cd ~/ros2_ws
colcon build --packages-up-to navmap_core navmap_ros navmap_rviz_plugin navmap_tools navmap_examples

# Source workspace
source install/setup.bash
Dependencies
- C++23 compiler
- Eigen3
- ROS 2 (tested with Humble, Iron, Jazzy)
- RViz2 (for the visualization plugin)
- PCL (for mesh construction utilities)
🚀 Usage (C++ API)
This section shows small, self-contained snippets that demonstrate how to create a NavMap, add geometry, attach layers, query values, and locate the triangle (NavCel) corresponding to a 3D position.
Note: After modifying geometry (vertices, triangles, or surfaces), always call
rebuild_geometry_accels()before performing queries such aslocate_navcel()orraycast().
1. Create a minimal NavMap (single square floor with two triangles)
```cpp
File truncated at 100 lines see the full file
CONTRIBUTING
|
|
NavMap repositorynavmap_core navmap_examples navmap_ros navmap_ros_interfaces navmap_rviz_plugin navmap_tools |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/NavMap.git |
| VCS Type | git |
| VCS Version | kilted |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| navmap_core | 0.6.0 |
| navmap_examples | 0.6.0 |
| navmap_ros | 0.6.0 |
| navmap_ros_interfaces | 0.6.0 |
| navmap_rviz_plugin | 0.6.0 |
| navmap_tools | 0.6.0 |
README
NavMap
NavMap is an open-source C++ and ROS 2 library for representing navigable surfaces for mobile robot navigation and localization. Unlike classic grid-based maps, NavMap stores the environment as triangular meshes (NavCels), enabling efficient queries and multi-surface environments (e.g., multi-floor buildings).
Funded by the European Union through the Horizon Europe programme under Grant Agreement No. 101070254 (CoreSense), and by MICIU/AEI/10.13039/501100011033 and ERDF/EU under grants PERMAP PID2024-161761OB-C21 and PLANNAV PID2024-161761OB-C22 (AURORAS).
✨ Features
- Triangular cell mesh representation with adjacency relations.
- Dynamic runtime layers: per-cell or per-vertex attributes (occupancy, elevation, cost, traversability, etc.).
- Locate API: find the NavCel under/around a 3D position using BVH acceleration and raycasting.
- Raytracing: Möller–Trumbore intersection with a simple BVH for efficiency.
- Multi-surface support: naturally supports multiple disconnected surfaces (e.g., separate floors).
📂 Repository structure
This repository is organized into several ROS 2 packages:
-
navmap_core/
Core C++ library implementing NavMap. Minimal dependencies (Eigen3). -
navmap_ros/
ROS 2 conversions and message definitions:-
navmap::NavMap↔navmap_ros_interfaces::msg::NavMap -
nav_msgs::msg::OccupancyGrid↔navmap::NavMap
-
-
navmap_rviz_plugin/
RViz2 plugin for visualization of NavMap messages:- Displays surfaces and layers.
- Optional per-cell normal rendering.
- Layer-based coloring.
-
navmap_tools/
Tools and utilities for building and testing NavMaps (mesh import/export, conversions, etc.) -
navmap_examples/
Practical examples demonstrating the usage of NavMap, both core C++ API and ROS 2 integrations.
⚙️ Build instructions
NavMap can be built as a standalone C++ library or within a ROS 2 workspace.
ROS 2 colcon build
# Clone into your ROS 2 workspace
cd ~/ros2_ws/src
git clone https://github.com/<your-org>/NavMap.git

# Build
cd ~/ros2_ws
colcon build --packages-up-to navmap_core navmap_ros navmap_rviz_plugin navmap_tools navmap_examples

# Source workspace
source install/setup.bash
Dependencies
- C++23 compiler
- Eigen3
- ROS 2 (tested with Humble, Iron, Jazzy)
- RViz2 (for the visualization plugin)
- PCL (for mesh construction utilities)
🚀 Usage (C++ API)
This section shows small, self-contained snippets that demonstrate how to create a NavMap, add geometry, attach layers, query values, and locate the triangle (NavCel) corresponding to a 3D position.
Note: After modifying geometry (vertices, triangles, or surfaces), always call
rebuild_geometry_accels()before performing queries such aslocate_navcel()orraycast().
1. Create a minimal NavMap (single square floor with two triangles)
```cpp
File truncated at 100 lines see the full file
CONTRIBUTING
|
|
NavMap repositorynavmap_core navmap_examples navmap_ros navmap_ros_interfaces navmap_rviz_plugin navmap_tools |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/NavMap.git |
| VCS Type | git |
| VCS Version | lyrical |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| navmap_core | 0.6.0 |
| navmap_examples | 0.6.0 |
| navmap_ros | 0.6.0 |
| navmap_ros_interfaces | 0.6.0 |
| navmap_rviz_plugin | 0.6.0 |
| navmap_tools | 0.6.0 |
README
NavMap
NavMap is an open-source C++ and ROS 2 library for representing navigable surfaces for mobile robot navigation and localization. Unlike classic grid-based maps, NavMap stores the environment as triangular meshes (NavCels), enabling efficient queries and multi-surface environments (e.g., multi-floor buildings).
Funded by the European Union through the Horizon Europe programme under Grant Agreement No. 101070254 (CoreSense), and by MICIU/AEI/10.13039/501100011033 and ERDF/EU under grants PERMAP PID2024-161761OB-C21 and PLANNAV PID2024-161761OB-C22 (AURORAS).
✨ Features
- Triangular cell mesh representation with adjacency relations.
- Dynamic runtime layers: per-cell or per-vertex attributes (occupancy, elevation, cost, traversability, etc.).
- Locate API: find the NavCel under/around a 3D position using BVH acceleration and raycasting.
- Raytracing: Möller–Trumbore intersection with a simple BVH for efficiency.
- Multi-surface support: naturally supports multiple disconnected surfaces (e.g., separate floors).
📂 Repository structure
This repository is organized into several ROS 2 packages:
-
navmap_core/
Core C++ library implementing NavMap. Minimal dependencies (Eigen3). -
navmap_ros/
ROS 2 conversions and message definitions:-
navmap::NavMap↔navmap_ros_interfaces::msg::NavMap -
nav_msgs::msg::OccupancyGrid↔navmap::NavMap
-
-
navmap_rviz_plugin/
RViz2 plugin for visualization of NavMap messages:- Displays surfaces and layers.
- Optional per-cell normal rendering.
- Layer-based coloring.
-
navmap_tools/
Tools and utilities for building and testing NavMaps (mesh import/export, conversions, etc.) -
navmap_examples/
Practical examples demonstrating the usage of NavMap, both core C++ API and ROS 2 integrations.
⚙️ Build instructions
NavMap can be built as a standalone C++ library or within a ROS 2 workspace.
ROS 2 colcon build
# Clone into your ROS 2 workspace
cd ~/ros2_ws/src
git clone https://github.com/<your-org>/NavMap.git

# Build
cd ~/ros2_ws
colcon build --packages-up-to navmap_core navmap_ros navmap_rviz_plugin navmap_tools navmap_examples

# Source workspace
source install/setup.bash
Dependencies
- C++23 compiler
- Eigen3
- ROS 2 (tested with Humble, Iron, Jazzy)
- RViz2 (for the visualization plugin)
- PCL (for mesh construction utilities)
🚀 Usage (C++ API)
This section shows small, self-contained snippets that demonstrate how to create a NavMap, add geometry, attach layers, query values, and locate the triangle (NavCel) corresponding to a 3D position.
Note: After modifying geometry (vertices, triangles, or surfaces), always call
rebuild_geometry_accels()before performing queries such aslocate_navcel()orraycast().
1. Create a minimal NavMap (single square floor with two triangles)
```cpp
File truncated at 100 lines see the full file
CONTRIBUTING
|
|
NavMap repositorynavmap_core navmap_examples navmap_ros navmap_ros_interfaces navmap_rviz_plugin navmap_tools |
ROS Distro
|
Repository Summary
| Description | |
| Checkout URI | https://github.com/EasyNavigation/NavMap.git |
| VCS Type | git |
| VCS Version | humble |
| Last Updated | 2026-10-08 |
| Dev Status | DEVELOPED |
| Released | RELEASED |
| Contributing |
Help Wanted (-)
Good First Issues (-) Pull Requests to Review (-) |
Packages
| Name | Version |
|---|---|
| navmap_core | 0.6.0 |
| navmap_examples | 0.6.0 |
| navmap_ros | 0.6.0 |
| navmap_ros_interfaces | 0.6.0 |
| navmap_rviz_plugin | 0.6.0 |
| navmap_tools | 0.6.0 |
README
NavMap
NavMap is an open-source C++ and ROS 2 library for representing navigable surfaces for mobile robot navigation and localization. Unlike classic grid-based maps, NavMap stores the environment as triangular meshes (NavCels), enabling efficient queries and multi-surface environments (e.g., multi-floor buildings).
Funded by the European Union through the Horizon Europe programme under Grant Agreement No. 101070254 (CoreSense), and by MICIU/AEI/10.13039/501100011033 and ERDF/EU under grants PERMAP PID2024-161761OB-C21 and PLANNAV PID2024-161761OB-C22 (AURORAS).
✨ Features
- Triangular cell mesh representation with adjacency relations.
- Dynamic runtime layers: per-cell or per-vertex attributes (occupancy, elevation, cost, traversability, etc.).
- Locate API: find the NavCel under/around a 3D position using BVH acceleration and raycasting.
- Raytracing: Möller–Trumbore intersection with a simple BVH for efficiency.
- Multi-surface support: naturally supports multiple disconnected surfaces (e.g., separate floors).
📂 Repository structure
This repository is organized into several ROS 2 packages:
-
navmap_core/
Core C++ library implementing NavMap. Minimal dependencies (Eigen3). -
navmap_ros/
ROS 2 conversions and message definitions:-
navmap::NavMap↔navmap_ros_interfaces::msg::NavMap -
nav_msgs::msg::OccupancyGrid↔navmap::NavMap
-
-
navmap_rviz_plugin/
RViz2 plugin for visualization of NavMap messages:- Displays surfaces and layers.
- Optional per-cell normal rendering.
- Layer-based coloring.
-
navmap_tools/
Tools and utilities for building and testing NavMaps (mesh import/export, conversions, etc.) -
navmap_examples/
Practical examples demonstrating the usage of NavMap, both core C++ API and ROS 2 integrations.
⚙️ Build instructions
NavMap can be built as a standalone C++ library or within a ROS 2 workspace.
ROS 2 colcon build
# Clone into your ROS 2 workspace
cd ~/ros2_ws/src
git clone https://github.com/<your-org>/NavMap.git

# Build
cd ~/ros2_ws
colcon build --packages-up-to navmap_core navmap_ros navmap_rviz_plugin navmap_tools navmap_examples

# Source workspace
source install/setup.bash
Dependencies
- C++23 compiler
- Eigen3
- ROS 2 (tested with Humble, Iron, Jazzy)
- RViz2 (for the visualization plugin)
- PCL (for mesh construction utilities)
🚀 Usage (C++ API)
This section shows small, self-contained snippets that demonstrate how to create a NavMap, add geometry, attach layers, query values, and locate the triangle (NavCel) corresponding to a 3D position.
Note: After modifying geometry (vertices, triangles, or surfaces), always call
rebuild_geometry_accels()before performing queries such aslocate_navcel()orraycast().
1. Create a minimal NavMap (single square floor with two triangles)
```cpp
File truncated at 100 lines see the full file